Explore performance details, construction highlights, applications, and technical information in one clear overview.
The Vacuum Gripper VMG is a high-performance solution designed for the reliable conveyance of large workpieces. Its versatile design enables secure handling across a wide range of materials and shapes, making it ideal for industrial automation environments where precision and stability are critical.
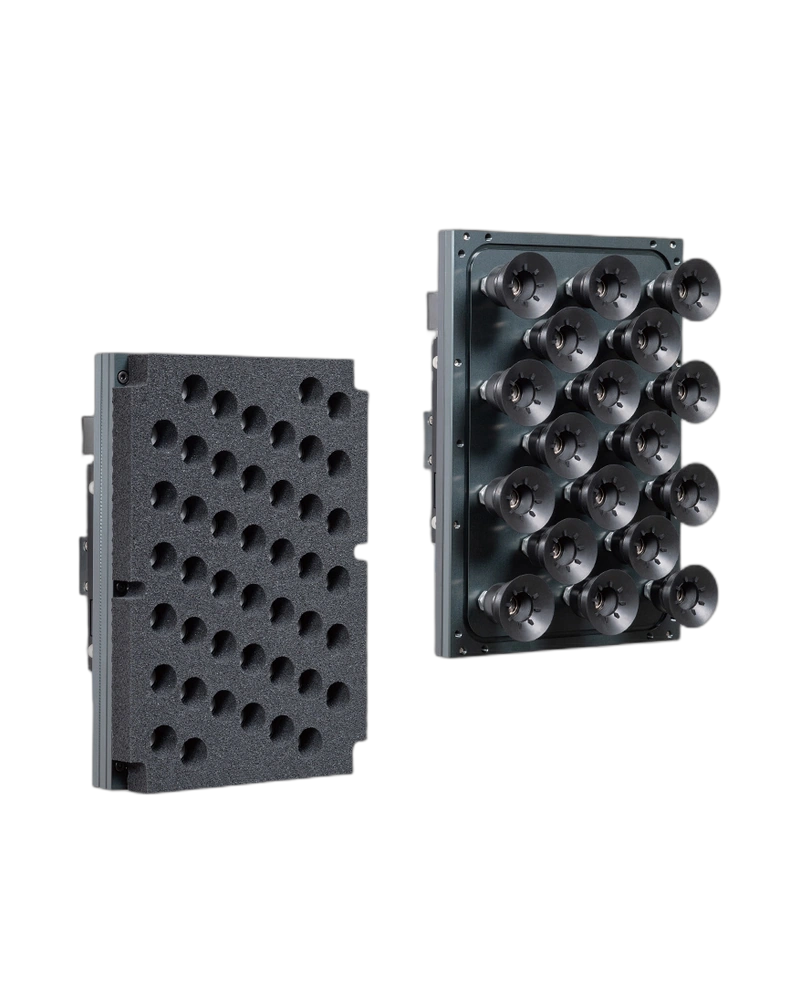
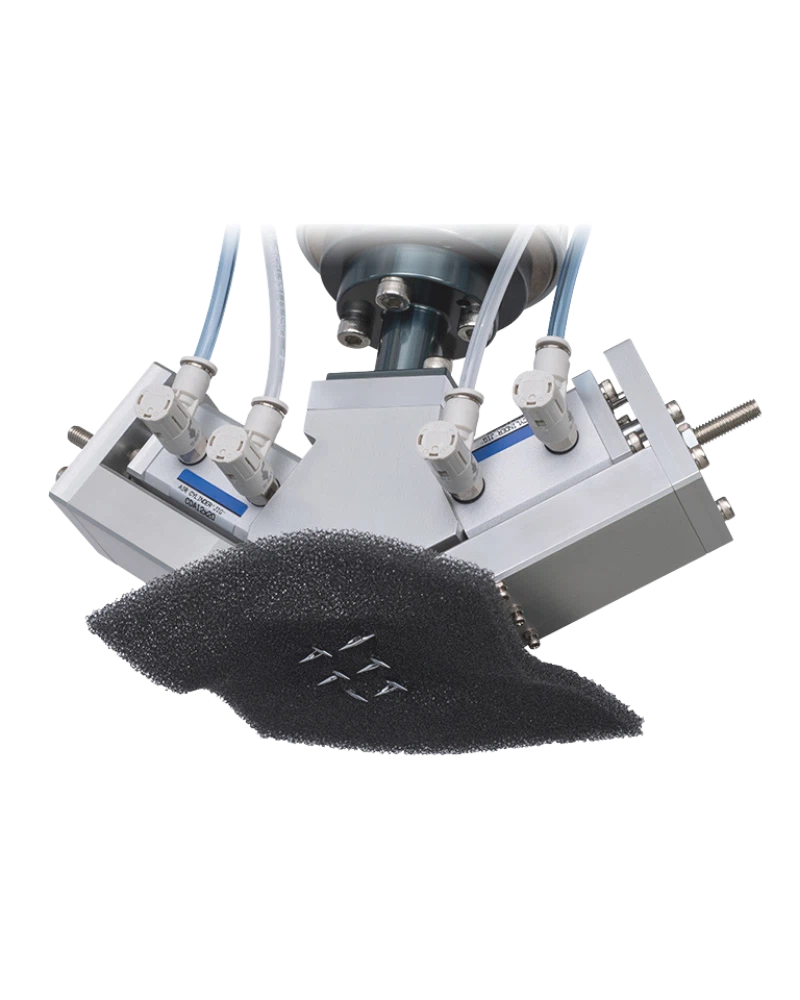
The VMG features two distinct configurations: a whole surface sponge type and an arranged Vacuum Pads type. Both designs offer robust suction performance and adaptability to various workpiece geometries. The pad arrangement options include 5, 7, and 11 rows, allowing customization based on application requirements.
The gripper connects directly to end-of-arm tooling (EOAT) with P.C.D. diameters of 31.5, 40, 50, 80, and 100. This direct interface ensures a secure mechanical fit and simplifies integration into existing robotic systems without additional adapters or modifications.
The VMG is available in two vacuum generation types: built-in vacuum generator and vacuum pump compatible. The built-in model delivers a maximum suction flow rate of 760L/min (*1), capable of securely adsorbing even permeable workpieces such as corrugated cardboard (*2). For pump-compatible models, the operating vacuum pressure range is -100 to 0 kPa. Operating pressure for the built-in generator is specified at 0.5 MPa (rated supply pressure) within a range of 0.3–0.7 MPa.
Available pad sizes include 260 x 180 mm, 370 x 250 mm, and 570 x 380 mm. The gripper is offered in both sponge and arranged vacuum pad types with row configurations of 5, 7, or 11 rows to match specific workpiece dimensions and handling needs.
Installation is simplified through a sliding fit into the flange mounting plate secured to the robot arm. This design improves operational ease and safety by eliminating complex alignment procedures. An optional Screw Plug is available for Aligned vacuum pad types, enabling unsuctioning pads to be used as cushioning during handling.
| Specification | Details |
|---|---|
| Fluid medium | Air, Vacuum*1 |
| Operating pressure range | 0.3
Recommended products
Related Products
CategoryBrowse product families and jump into the exact catalog section you need. |