Explore performance details, construction highlights, applications, and technical information in one clear overview.
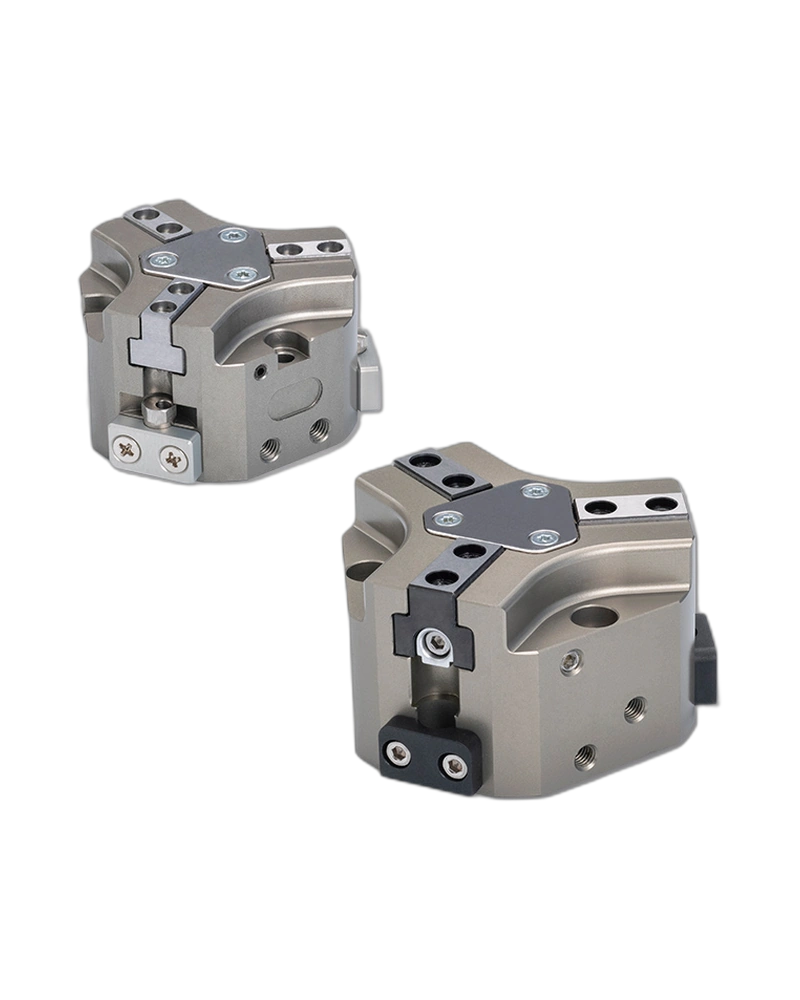
The Parallel Gripper with 3-finger is designed specifically for gripping cylindrical work-pieces with precision and reliability. Its unique wedge-cam mechanism, driven by a large-diameter round piston, delivers high gripping force while maintaining consistent performance across a range of applications in industrial automation and robotic systems.
The gripper is constructed using robust materials to ensure durability under operational conditions. It features a solid-state design with internal wiring options for both 2-wire and 3-wire configurations. The housing is engineered to support repeated cycles without degradation, and all components are designed to withstand environmental exposure within specified temperature ranges.
The gripper includes a standard sensor switch and an EOAT (End of Arm Tooling) mounting flange, which are available as non-standard items and must be purchased separately. Direct piping for EOAT integration is also provided, enabling seamless connection to robotic end-effectors without the need for additional adapters or modifications.
Operating characteristics include a double-acting design using air as the fluid medium, with an operating pressure range of 0.2
| Specification | Details |
|---|---|
| Acting type | Double-acting |
| Fluid medium | Air |
| Operating pressure range | 0.2
Recommended products
Related Products
CategoryBrowse product families and jump into the exact catalog section you need. |