Explore performance details, construction highlights, applications, and technical information in one clear overview.
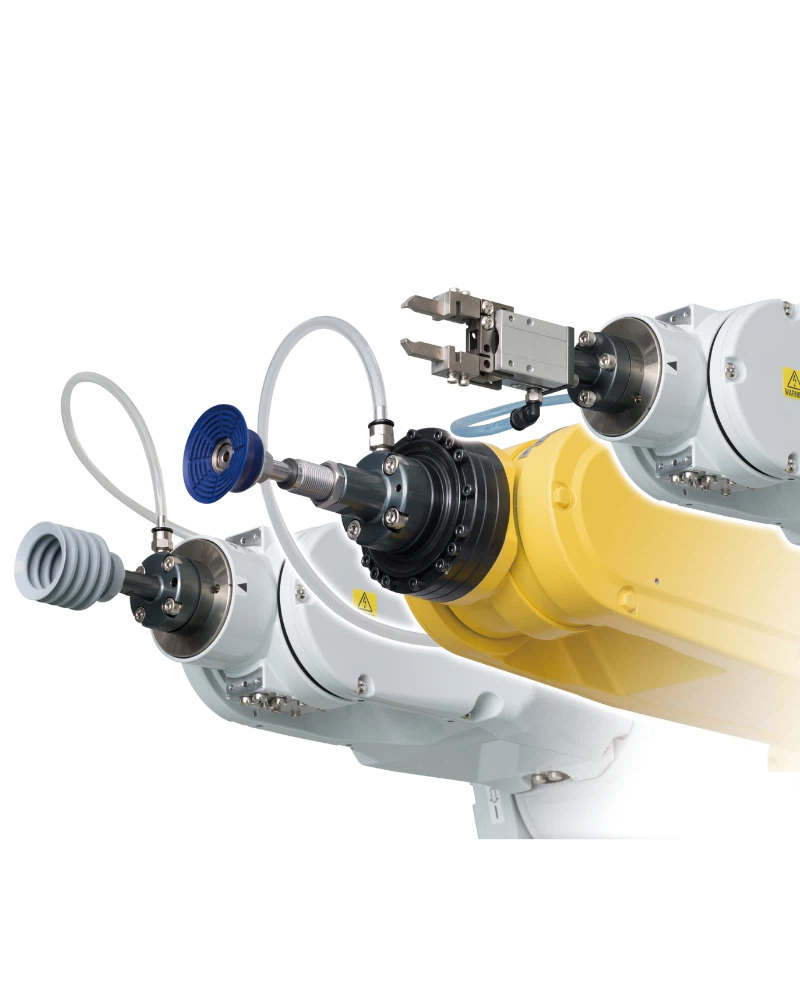
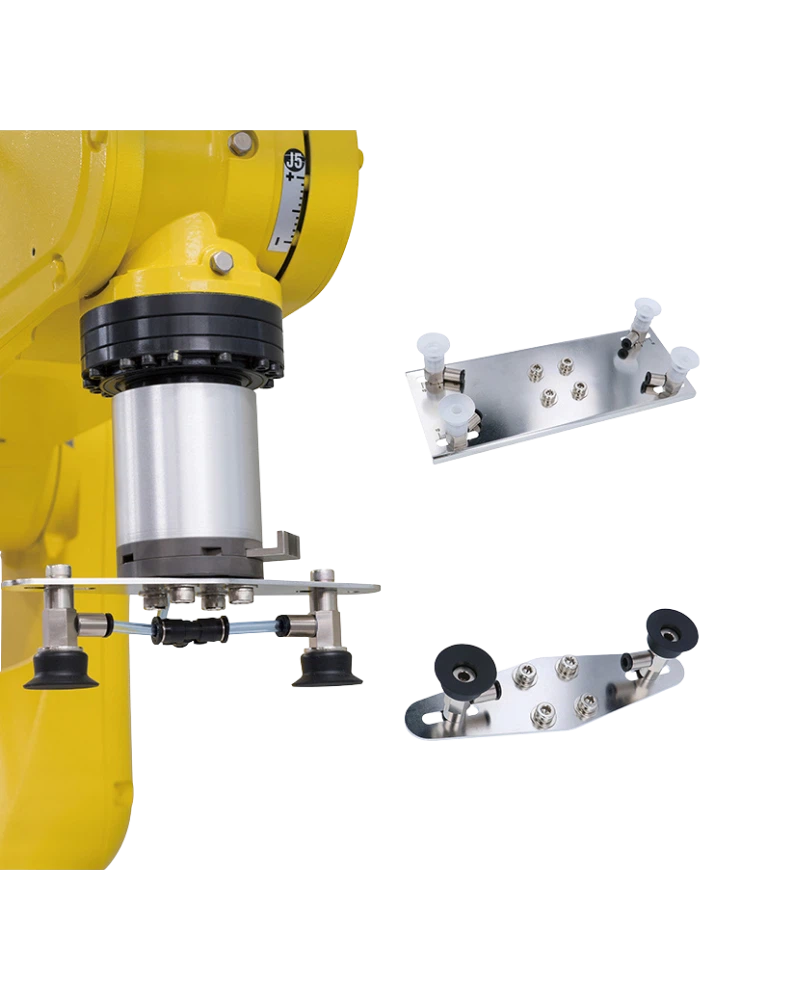
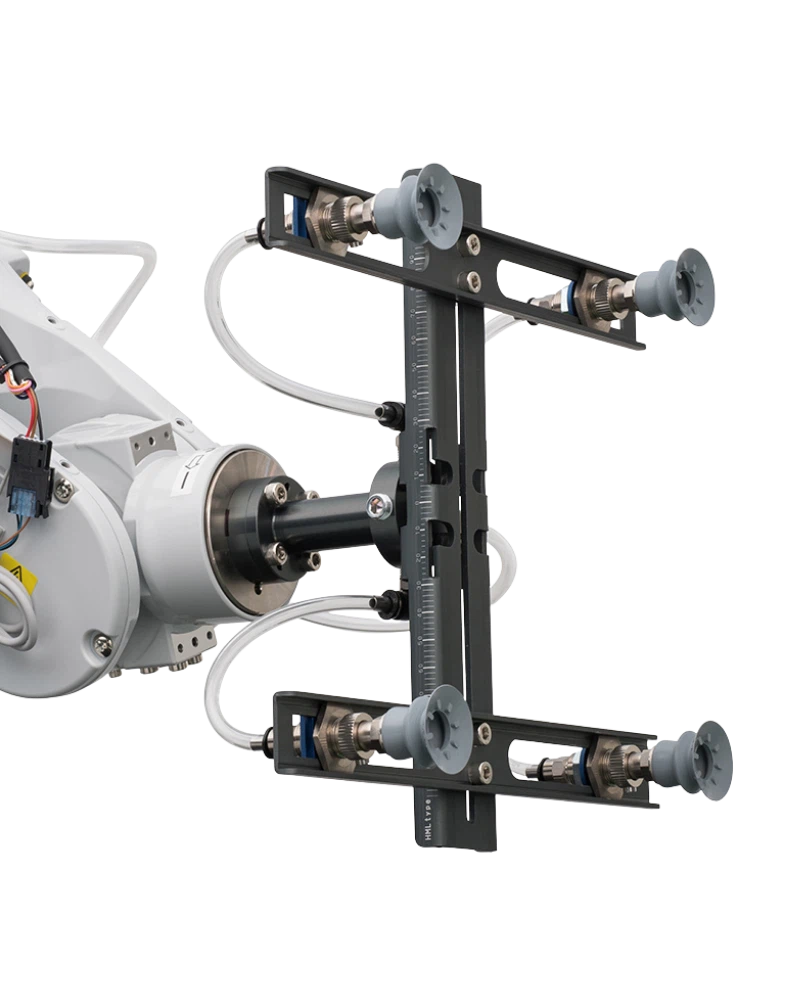
The HS configuration is a PISCO robotic-arm interface intended to mount one vacuum pad or one gripper at the end of a robot arm. It is designed to provide a compact mechanical interface between the robot and the selected end-of-arm tool.
PISCO specifies a direct mounting pattern with PCD 31.5 and M5 mounting for a piece of vacuum pad or gripper. Conversion flanges are available for the robot manufacturer selected for the installation.
The HS product is a mechanical mounting/interface component, so its pneumatic performance depends on the installed vacuum pad or gripper. The exact robot-side conversion flange and end-tool connection must be selected for the machine configuration.
Install the HS interface with the correct robot-side flange and tighten the end-of-arm tool according to the PISCO mechanical installation procedure. Verify tool clearance and the single-pad/single-gripper mounting arrangement before operation.
| Specification | Details |
|---|---|
| Product type | Robotic Arm / HS mounting interface |
| End tool capacity | One piece of Vacuum Pad or Gripper |
| Direct mounting | PCD 31.5, M5 mounting |
| Robot compatibility | Conversion flange available for each robot manufacturer |
| Pneumatic rating | Depends on connected vacuum pad or gripper |
Browse product families and jump into the exact catalog section you need.